Notes from the garage.
I manage a software team at Amazon Leo. On nights and weekends I build
robots, and write down how it is going — what worked, what did not, and
the parts I got wrong.
Mike Moore
Software development manager, Amazon Leo · Seattle
A single arm on a bench that swings itself up and balances. A brushless
motor, an encoder, and a Rust control loop on a Raspberry Pi at 200 Hz.
It first balanced on 1 September 2026. It now runs five swing-ups a run
under a hardware-in-the-loop regression gate, and the posts are about
the places where the simulator and the bench disagreed.
Overboard
Starting
A self-balancing one-wheel board. The same problem as the pendulum,
except the pendulum is me. Sim-first again, and this time the failure
modes matter rather more. Nothing written yet.
nothing written yet
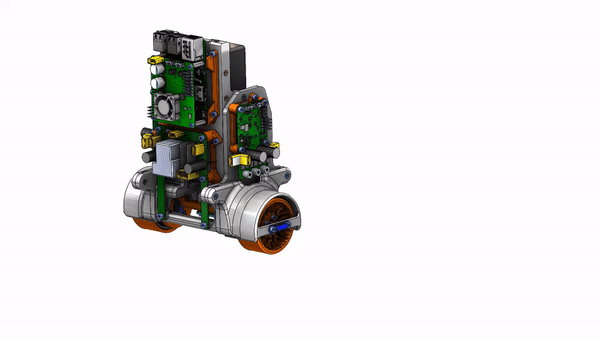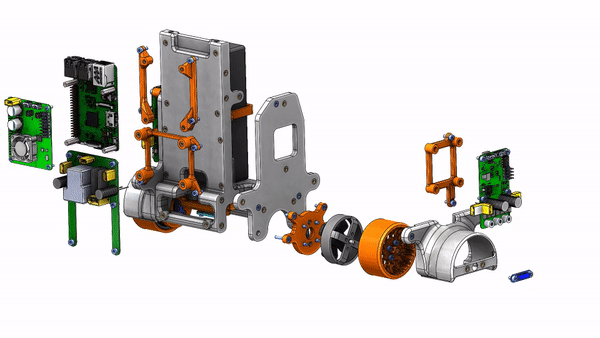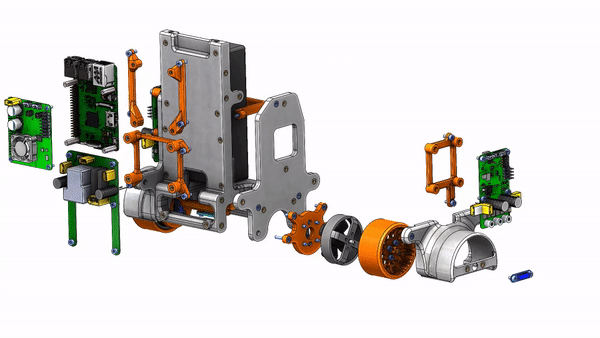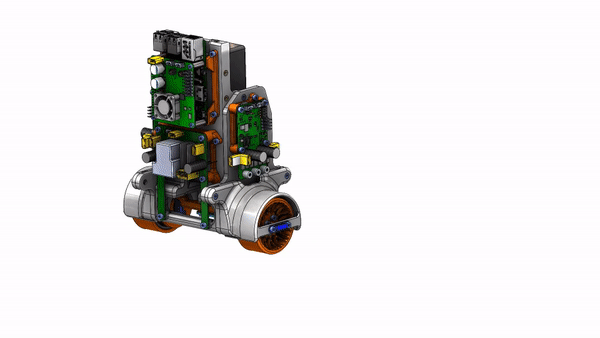
A two-wheeled balancing robot built so students and hobbyists could
play with feedback control on something real. Open source, with a
Gazebo simulation and a real-time controller on a Pi. The clip is the
sim above and the robot below, driving the same square — which is
where the sim-first habit came from.
POS-1
Archive
A quadcopter built from scratch, plus a flight simulator written in
Unity because none of the good open-source ones existed yet.
archive · 2013–14
Get new posts by email
Notes on robotics and controls, and on things that have to
stay upright. One email per post, and nothing else.
Buttondown hosts the list. One click unsubscribes, any time.